Real → simulation → real / Laboratory
A laboratory,
rebuilt for learning.
I reconstructed this laboratory to use as an environment for robot training in simulation. Explore the visual reconstruction below, or follow the camera path through the room.
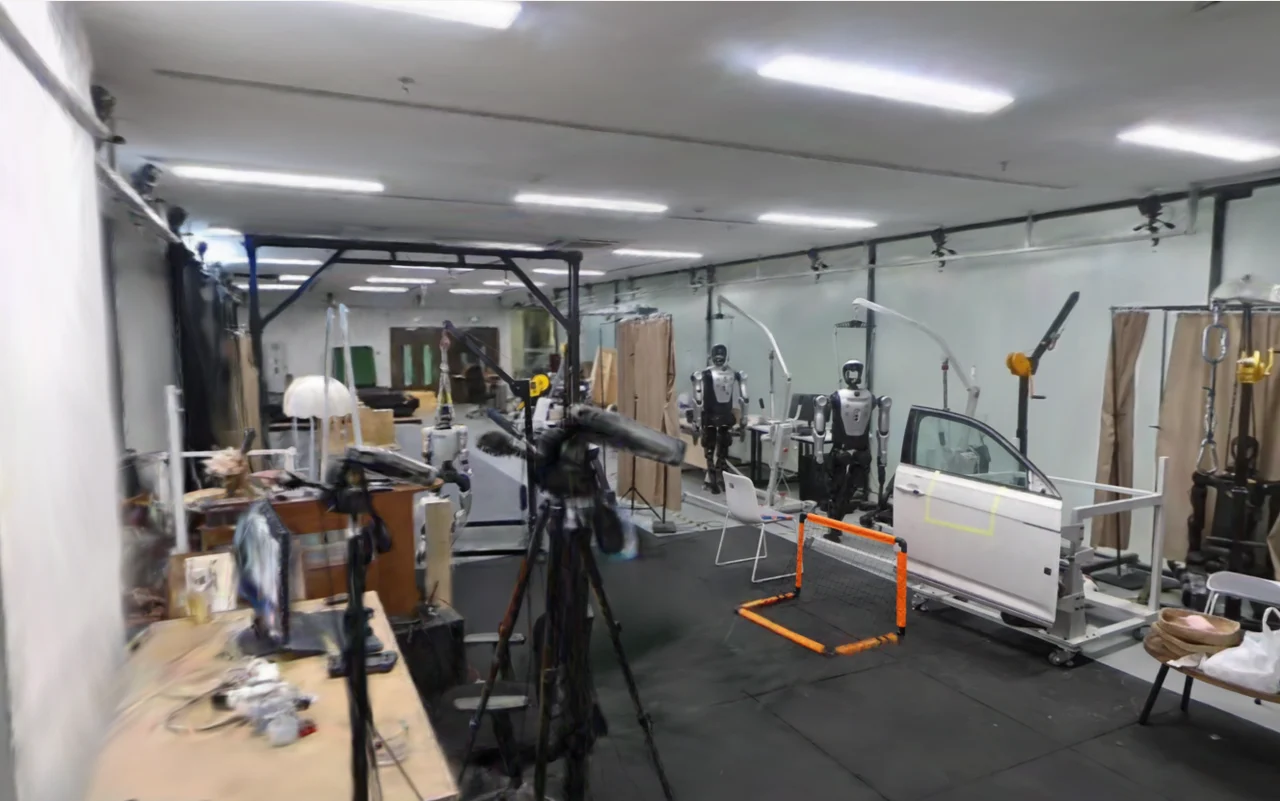
Click inside to use WASD. Drag to look; choose Orbit to rotate around a point. Arrow keys turn, Q/E change height. Wheel scrolls the page. Manual control pauses the tour.
More than a scene to look at
This laboratory and my reconstruction of an older adult’s home are both environments for robot learning. They are part of a real-to-sim-to-real approach: reconstruct a real place, train in simulation, and work toward bringing learned skills back into the real world.
The browser shows a visual copy of the laboratory. The training runs in a separate simulation environment; this viewer does not run a robot policy or a physics simulation.
About the reconstruction and web copy
This is a static scene made from 928,254 Gaussian primitives, with position, scale, rotation, opacity and view-dependent color. It is a reconstruction asset, not a conventional triangle mesh. Views near the captured interior are clearest; distant views and scene edges can reveal reconstruction artifacts.
The original PLY is 219.5 MiB. This viewer uses a locally converted SPZ v3 copy with SH degree 3 retained. The format quantizes parameters; keeping all bands does not make it lossless. The original file is unchanged.
Free flight has no collision model. The camera tour interpolates ordered poses from the reconstruction export. Playback timing is authored for viewing, not a replay of measured capture timestamps.